AI Robotic Arm
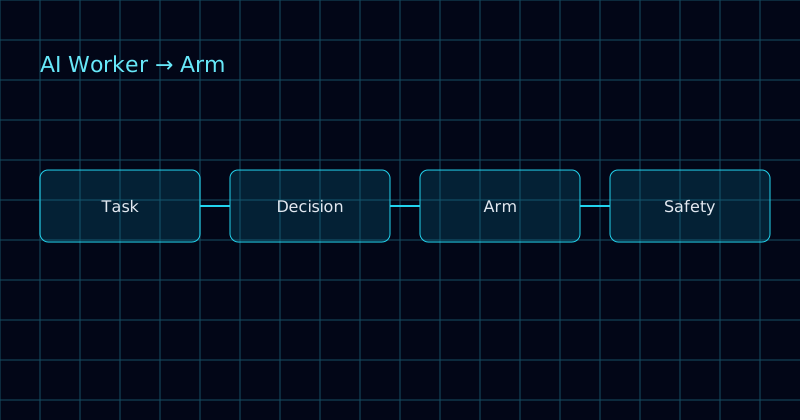
The arm is the limb of an AI worker. The worker understands the task and issues the action; the arm grasps, moves, and places.
System Capabilities
- AI worker
Understands the station task, chooses the next action, and commands the arm. Vision is the worker's perception, not an add-on assist for the arm.
- Arm execution
The arm only carries out the grasp, move, and place given by the worker.
- End effector
The gripper changes with the worker's current task. The control interface stays the same.
- Safety envelope
The worker may command the arm only inside the station safety envelope.
Solution Structure
Architecture
The upper layer is an AI worker: task understanding, perception, and action decisions. The arm is that worker's limb and only executes commands. Perception reaches the worker first and becomes an arm action. AI is not attached beside a conventional arm as an assist.
Metrics
Metrics will be added after measurement. Unverified numbers are omitted.
Interfaces
Task commands, arm control, coordinate frames, and the safety envelope.
Deployment
Deployed at a station as an AI worker that can act: pick and place, load and unload, and simple assembly.
Deliverables
Worker task interface, arm control, end-effector and safety-envelope notes, and joint commissioning.
Engagement
Define the tasks this worker must do, then set reach, end effector, and the safety zone.
Deliverables
AI worker arm pack
Integrable design, firmware, and interface notes for this solution.
Task interface, arm control, end effector, and safety envelope. Define the worker's tasks first, then commission the arm.
Technical Specifications
AI worker
Task understanding / action decisions
The worker understands the station task and issues actions. Vision feeds the worker, not an add-on assist for the arm.
Arm
Grasp / move / place
The arm only executes the worker's commands, and only inside the safety envelope.
Interfaces
Task command / arm control
Task commands, arm control, coordinate frames, and the safety envelope.
Metrics
Pending measurement
Task time, repeatability, and payload are filled in after the station is measured.
Technical engagement by scene
Share the site, interfaces, and cycle time. We confirm architecture and delivery scope from that.